Extending perception-aware processing towards information prioritisation, onboard intelligence, and autonomous decision-making for UAVs and robotic systems.
After Gabrielle: Autonomous Perception-Driven Drones with On-Board AI and Quantum-Sensed Soils for a Cyclone-Resilient Tairāwhiti
This project develops autonomous UAV systems combining onboard perception, embedded AI, visual sensing, and environmental sensing for cyclone-resilient agriculture and environmental monitoring. The research explores how autonomous platforms can prioritise relevant information, process it onboard, and support rapid decision-making under real-world computational and communication constraints.
Funded 2026 Project
Principal Investigator
Eastland Port and Qube: AI-Assisted Drone Inspection
Industry-connected research integrating UAVs, sensing, embedded systems, machine vision, and AI for infrastructure inspection and monitoring.
Industry Partnership
UAV Inspection
Agricultural and Rural Intelligent Systems
Research integrating sensing, embedded computing, remote monitoring, machine vision, and AI for agricultural and horticultural environments, supporting New Zealand primary-sector applications.
Agriculture
Intelligent Sensing
Visual Attention and Information Prioritisation
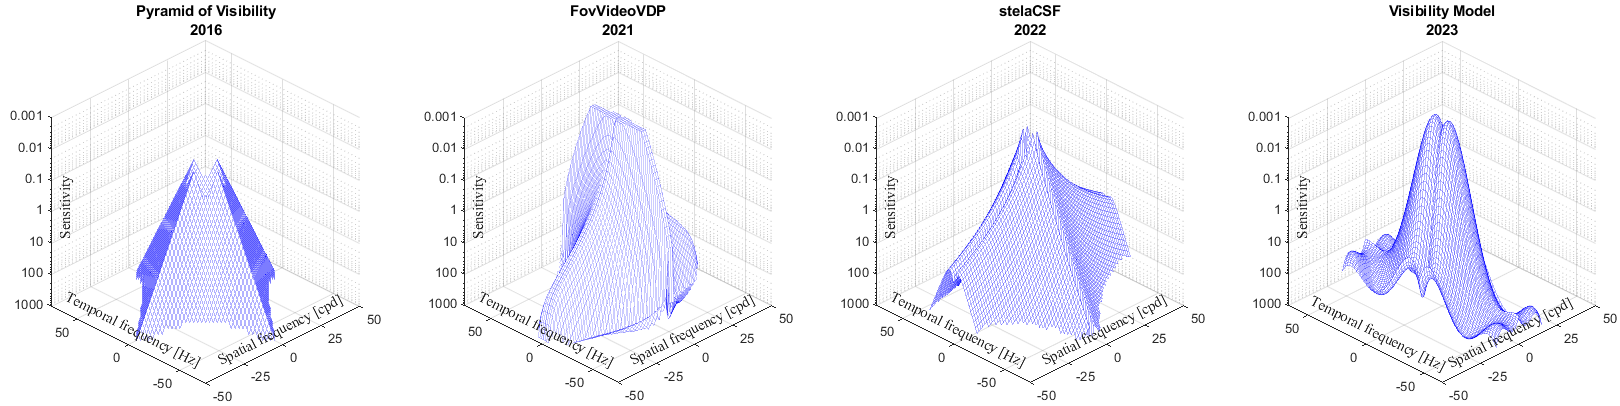
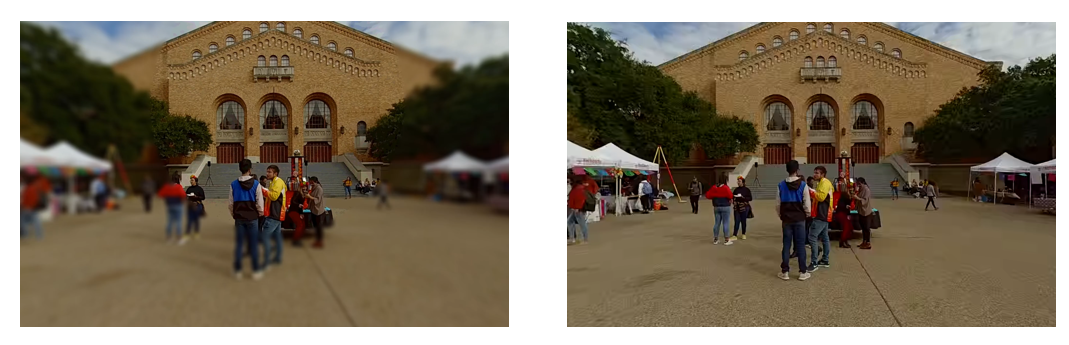
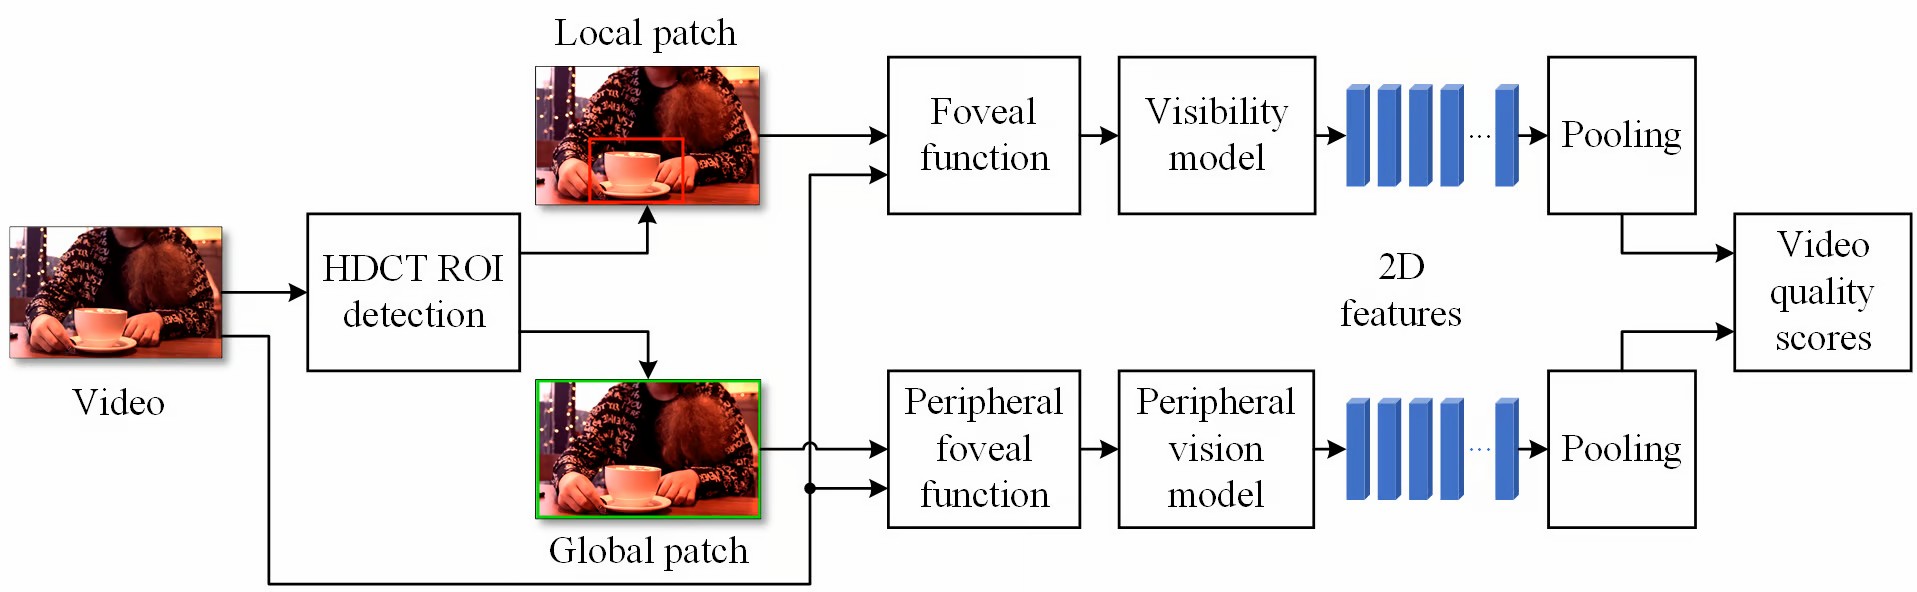
My next research stage focuses on visual attention and information prioritisation for autonomous systems. The goal is to allow robots and UAVs to identify decision-relevant information before full processing and respond more efficiently to important events.
Next Research Direction